I am a PhD student at Fudan University and Shanghai Innovation Institute, advised by Prof. Li Zhang. Prior to that, I received my Bachelor’s degree from Sun Yat-sen University. My research focuses on post-training embodied AI models and multi-system embodied intelligence.
I work closely with my senior labmates Junzhe Jiang and Jingyu Li.
🔥 News
- 2026.10: 🎉🎉 Forward Dynamics Models (FDM) is now available on arXiv, with code and a project page.
- 2026.09: 🎉🎉 TacPAC is now available on arXiv.
- 2026.07: 🎉🎉 DriveWeaver has been accepted by ECCV 2026.
- 2026.05: 🎉🎉 MoLA has been accepted by ICML 2026.
- 2025.06: 🎉🎉 BézierGS has been accepted by ICCV 2025.
📝 Publications
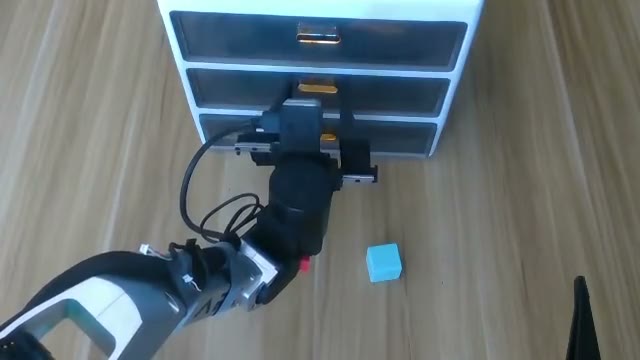
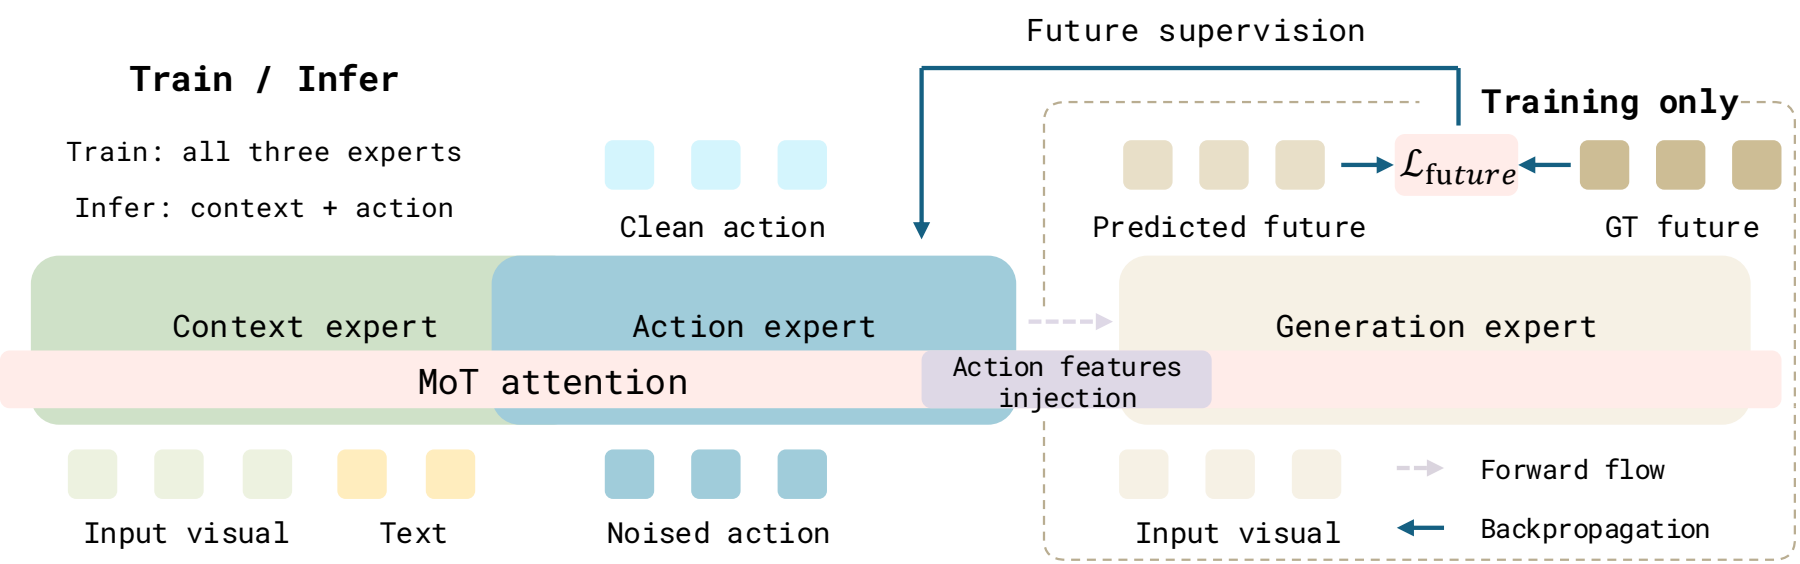
Zipei Ma, Junzhe Jiang, Jiahui Zhang, Juntong Zhang, Chun Gu, Bozhou Zhang, Jiankang Deng, Xiatian Zhu, Li Zhang
- TL;DR: We introduce FDM, which uses action-conditioned future prediction to supervise robotic policies during training and skips future generation at inference, achieving 99.4% average success on LIBERO and absolute gains of up to 13% on real-world tasks.
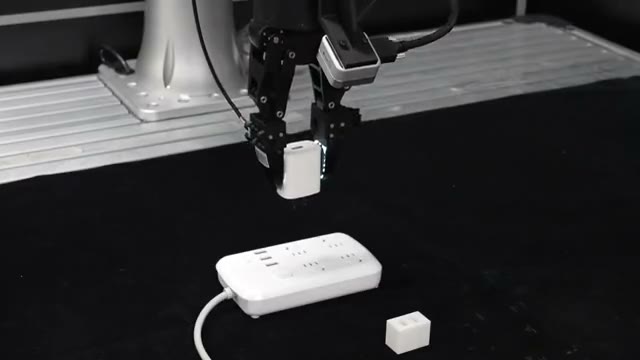
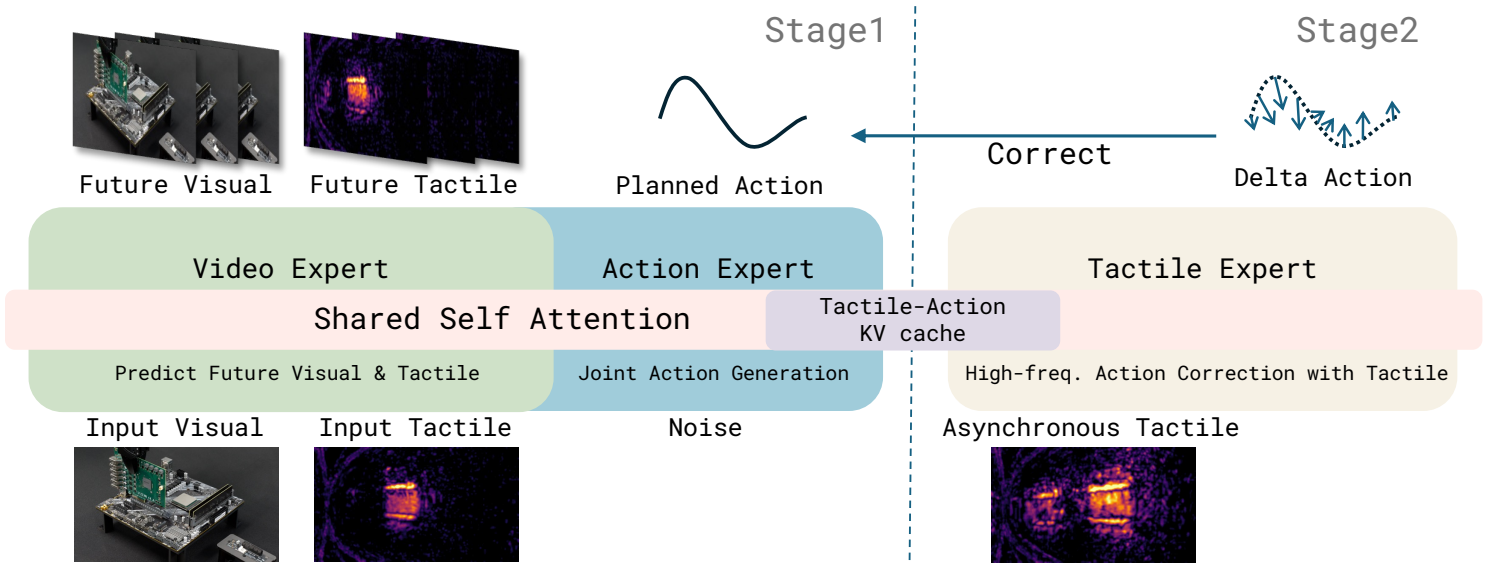
Zipei Ma, Xiaofei Wei, Junzhe Jiang, Shunlin Lu, Li Zhang
- TL;DR: We introduce TacPAC, which uses cached tactile predictions to interpret incoming touch and correct unexecuted actions in real time, improving average success from 22% to 64% across five contact-rich real-robot tasks.
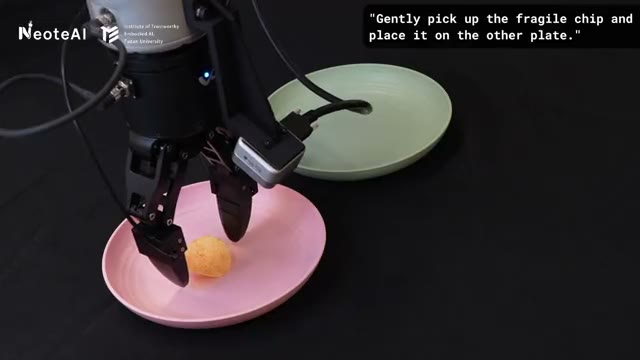
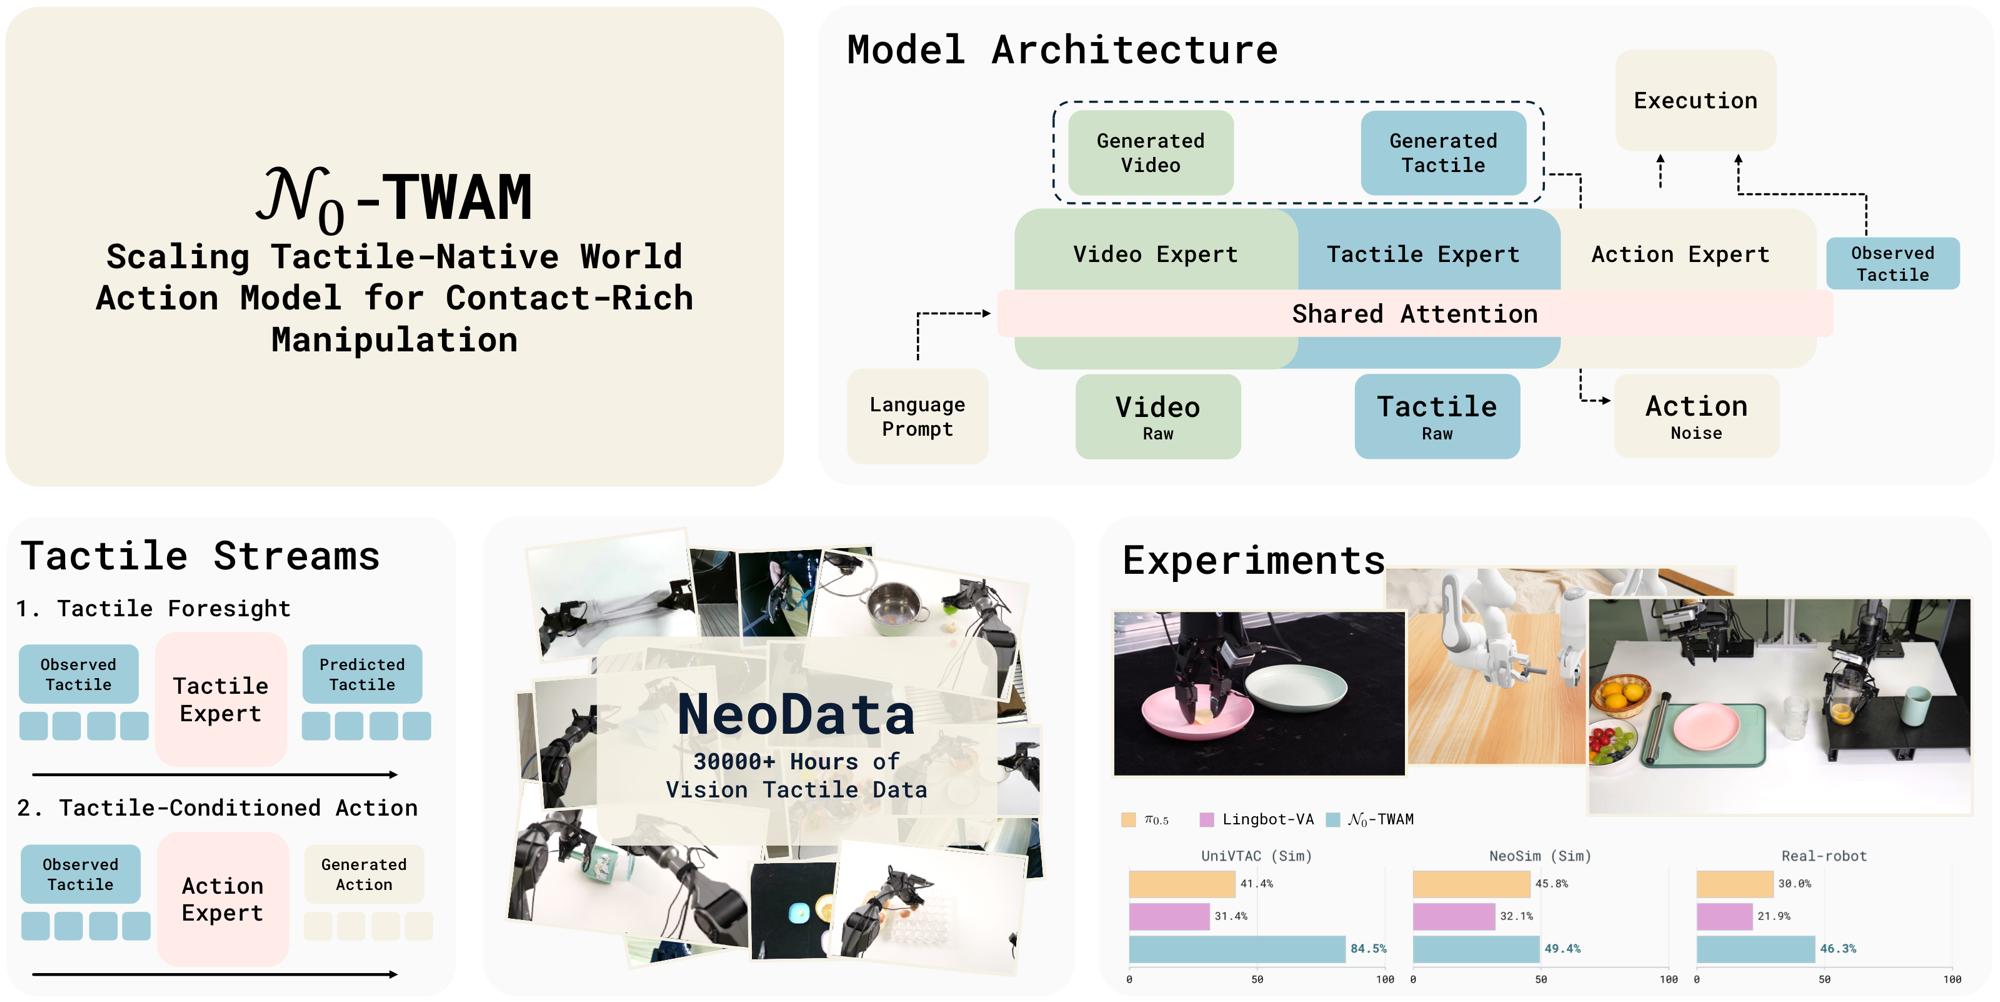
$\mathcal{N}_0$-TWAM: Scaling Tactile-Native World Action Model for Contact-Rich Manipulation
NeoteAI Team & Fudan TEAI Team
- TL;DR: We introduce $\mathcal{N}_0$-TWAM, a tactile-native world-action model that jointly predicts future vision, touch, and actions, enabling stronger contact-rich manipulation through large-scale visuo-tactile pretraining.
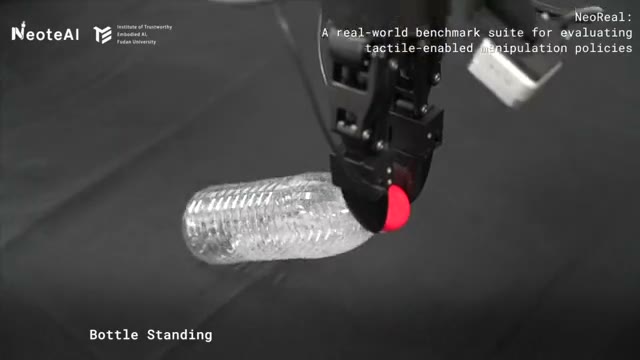
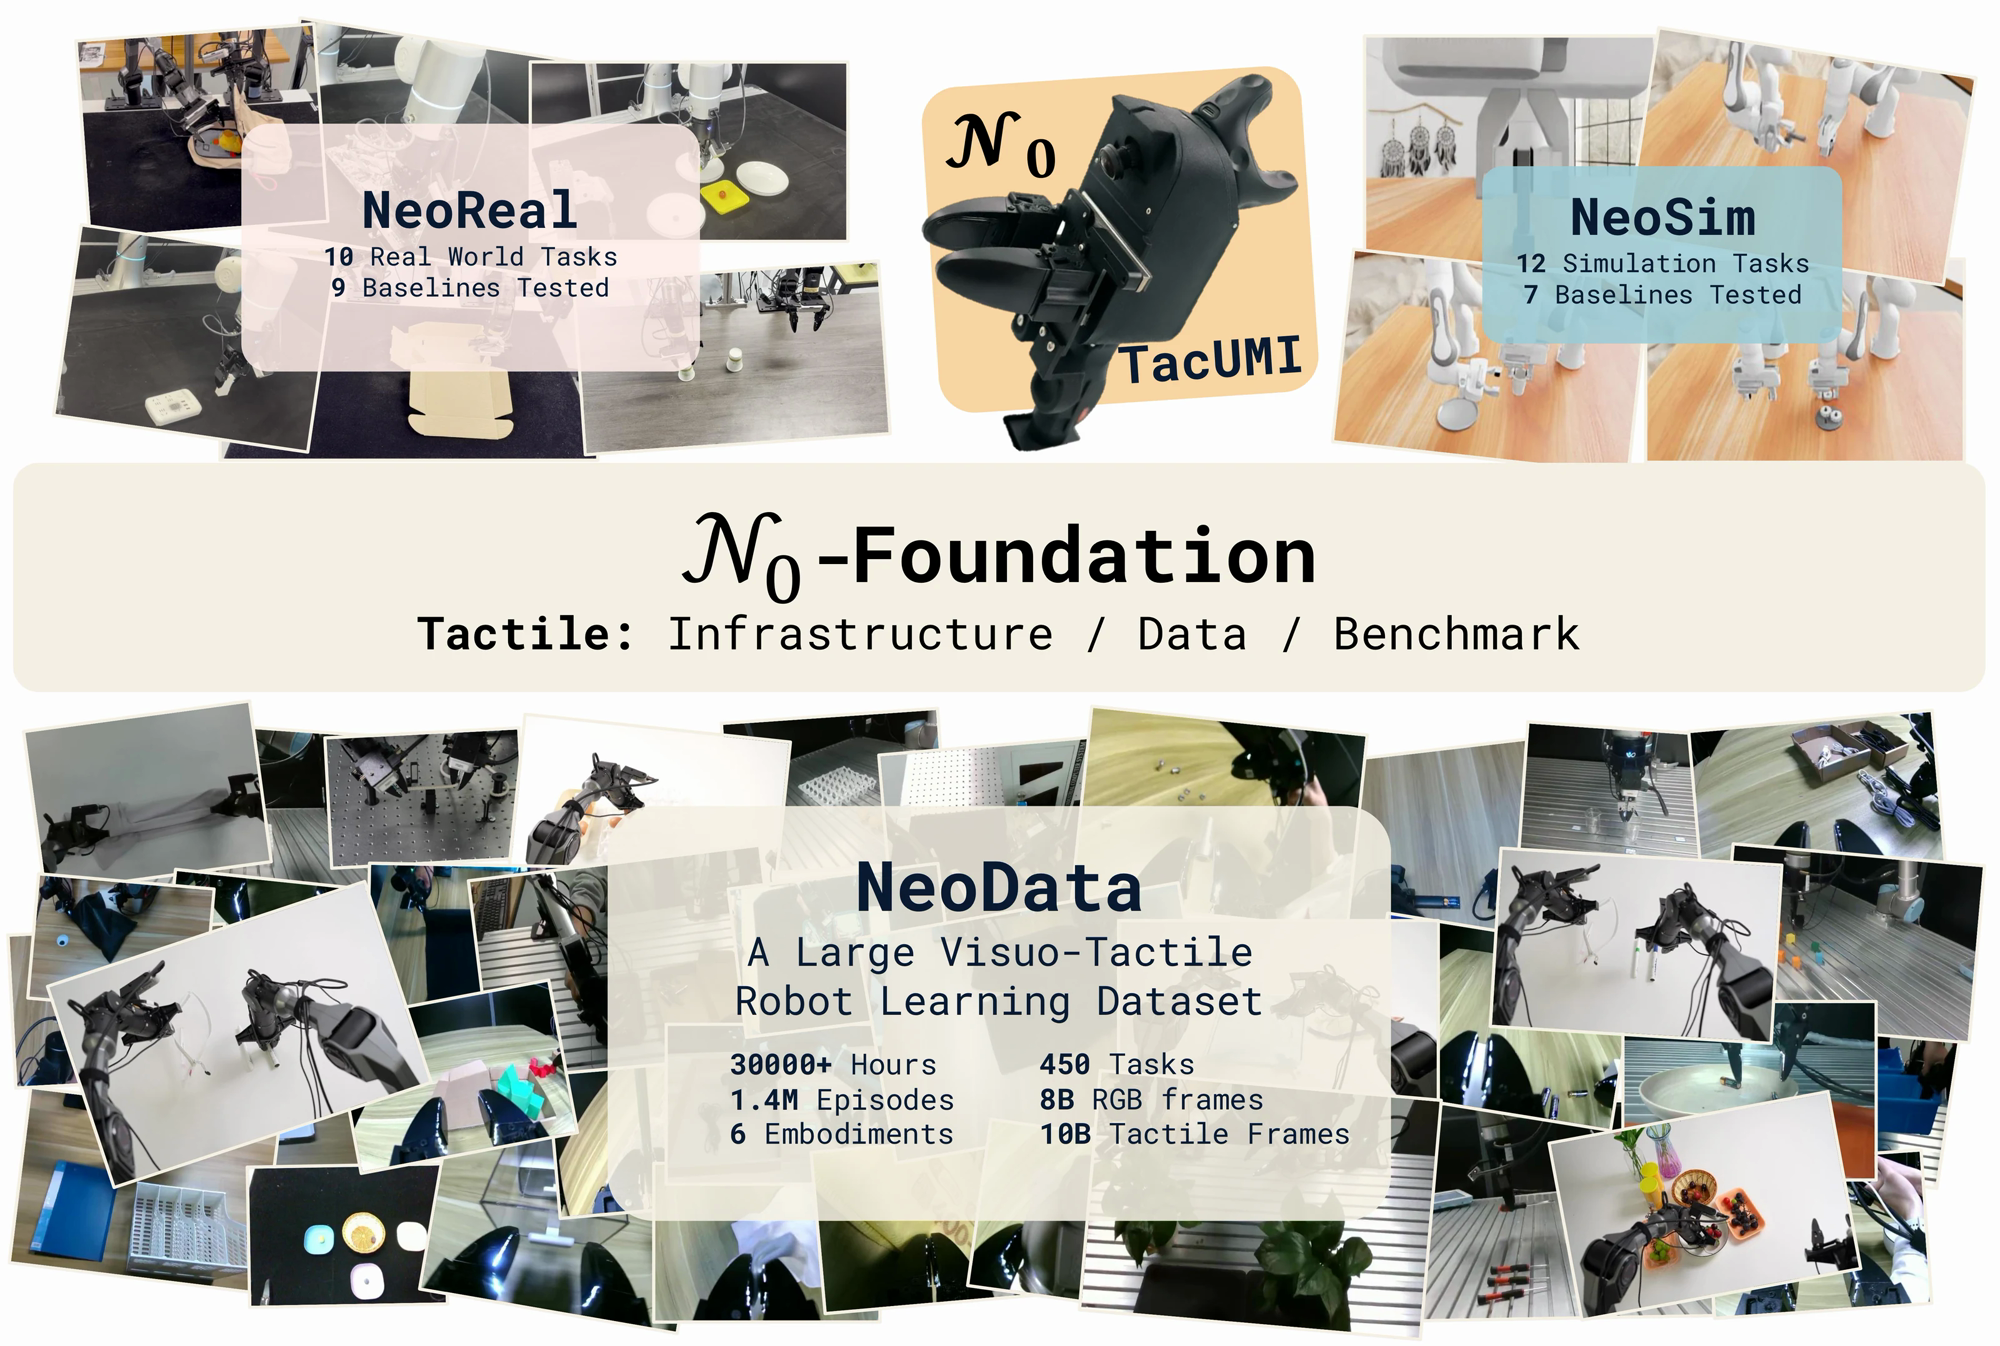
$\mathcal{N}_0$-Foundation: Towards the Age of Tactile Intelligence
NeoteAI Team & Fudan TEAI Team
- TL;DR: We present $\mathcal{N}_0$-Foundation, a tactile-centric foundation that unifies scalable sensing hardware, large-scale multimodal data, transferable tactile representations, and standardized real-world and simulated evaluation.
Junzhe Jiang, Zipei Ma, Zijie Pan, Li Zhang†
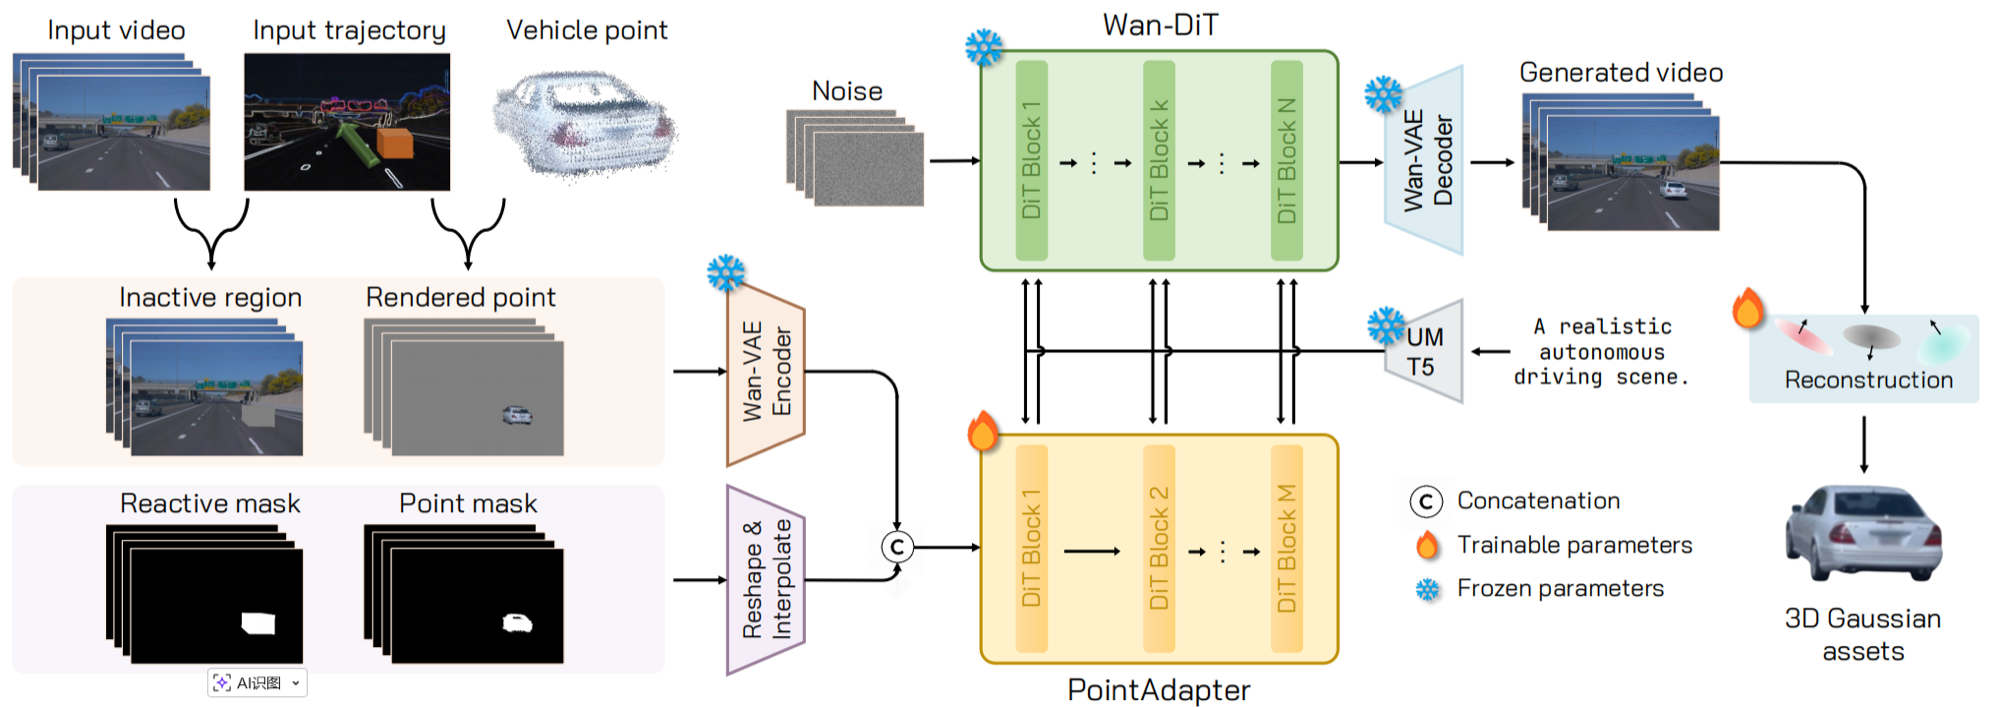
- TL;DR: We propose DriveWeaver, a point-cloud-conditioned video inpainting framework that inserts controllable, temporally consistent vehicles and extracts their 3D Gaussian representations for real-time autonomous driving simulation.
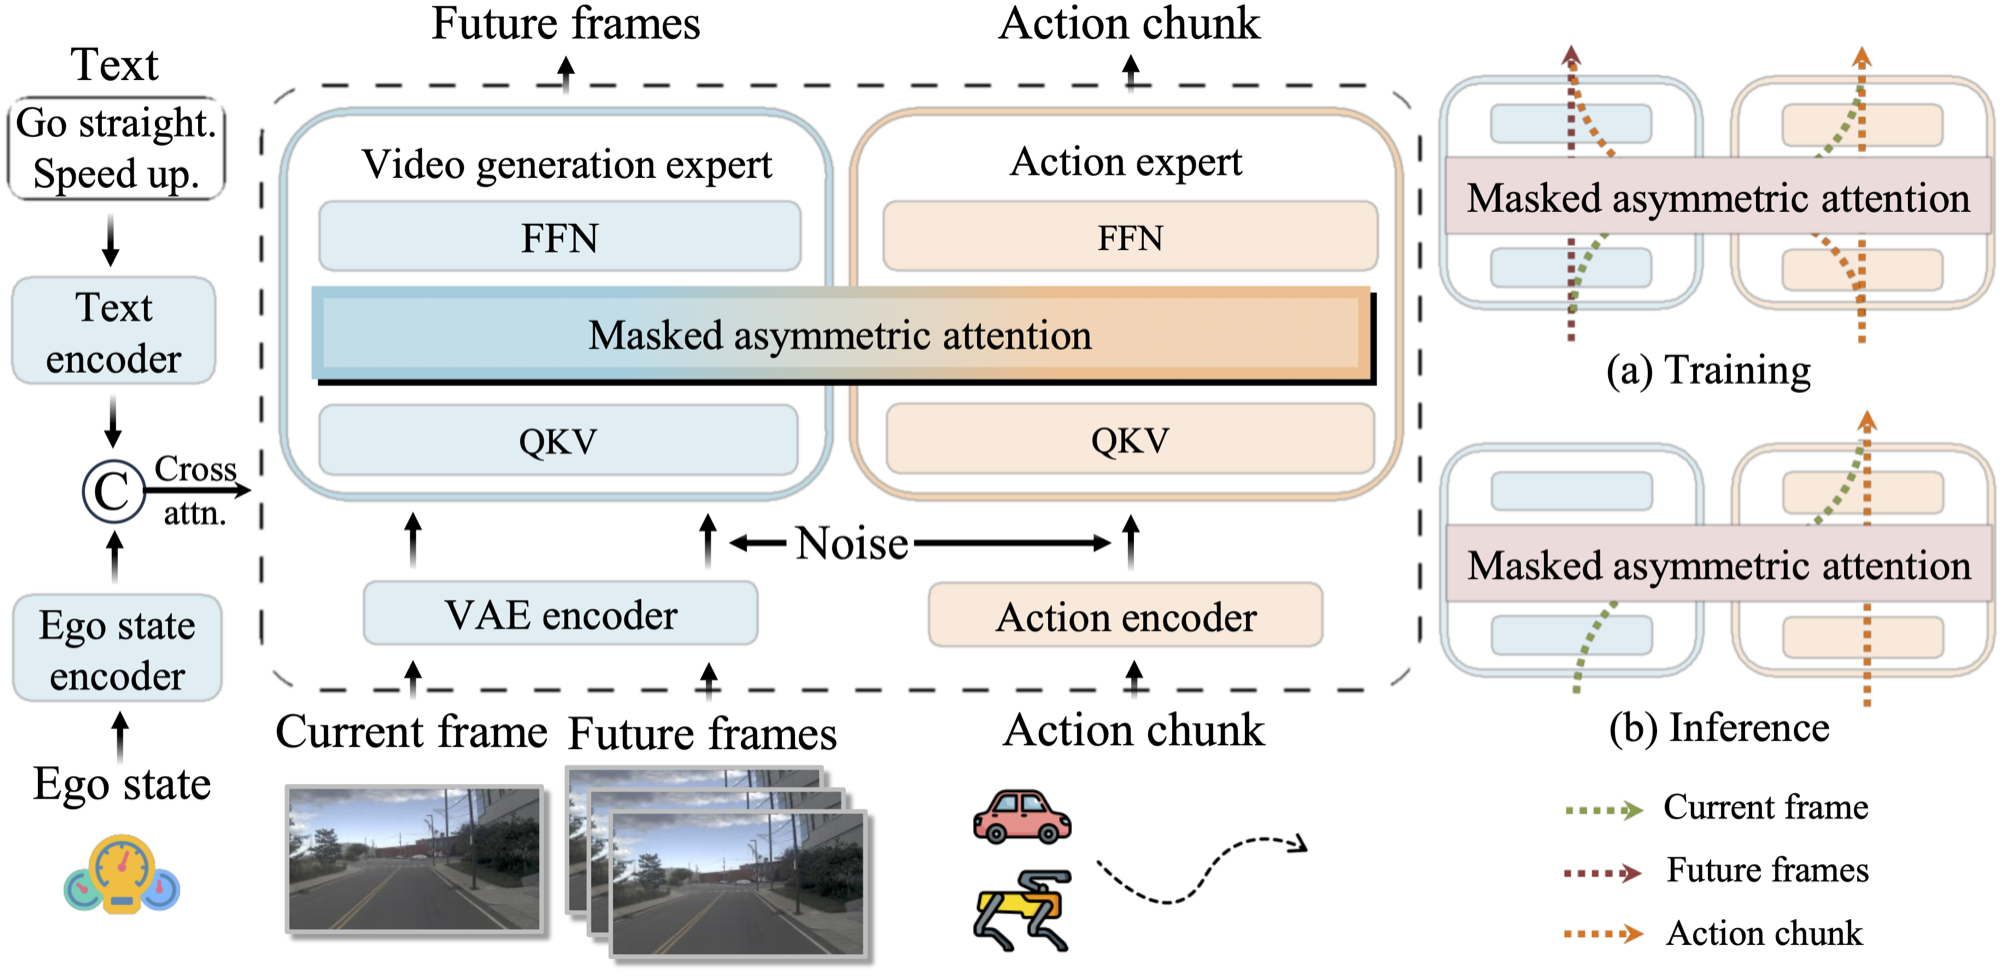
Metis: A Generalizable and Efficient World-Action Model for Autonomous Driving and Urban Navigation
Jingyu Li*, Zhe Liu*, Dongnan Hu, Junjie Wu, Zipei Ma, Wenxiao Wu, Chao Han, Zhihui Hao, Zhikang Liu, Kun Zhan, Jiankang Deng, Xiatian Zhu, Li Zhang†
- TL;DR: We introduce Metis, an efficient world-action model that decouples video generation and action prediction through specialized transformer experts and asymmetric attention, retaining world-model supervision during training while bypassing video generation at inference.
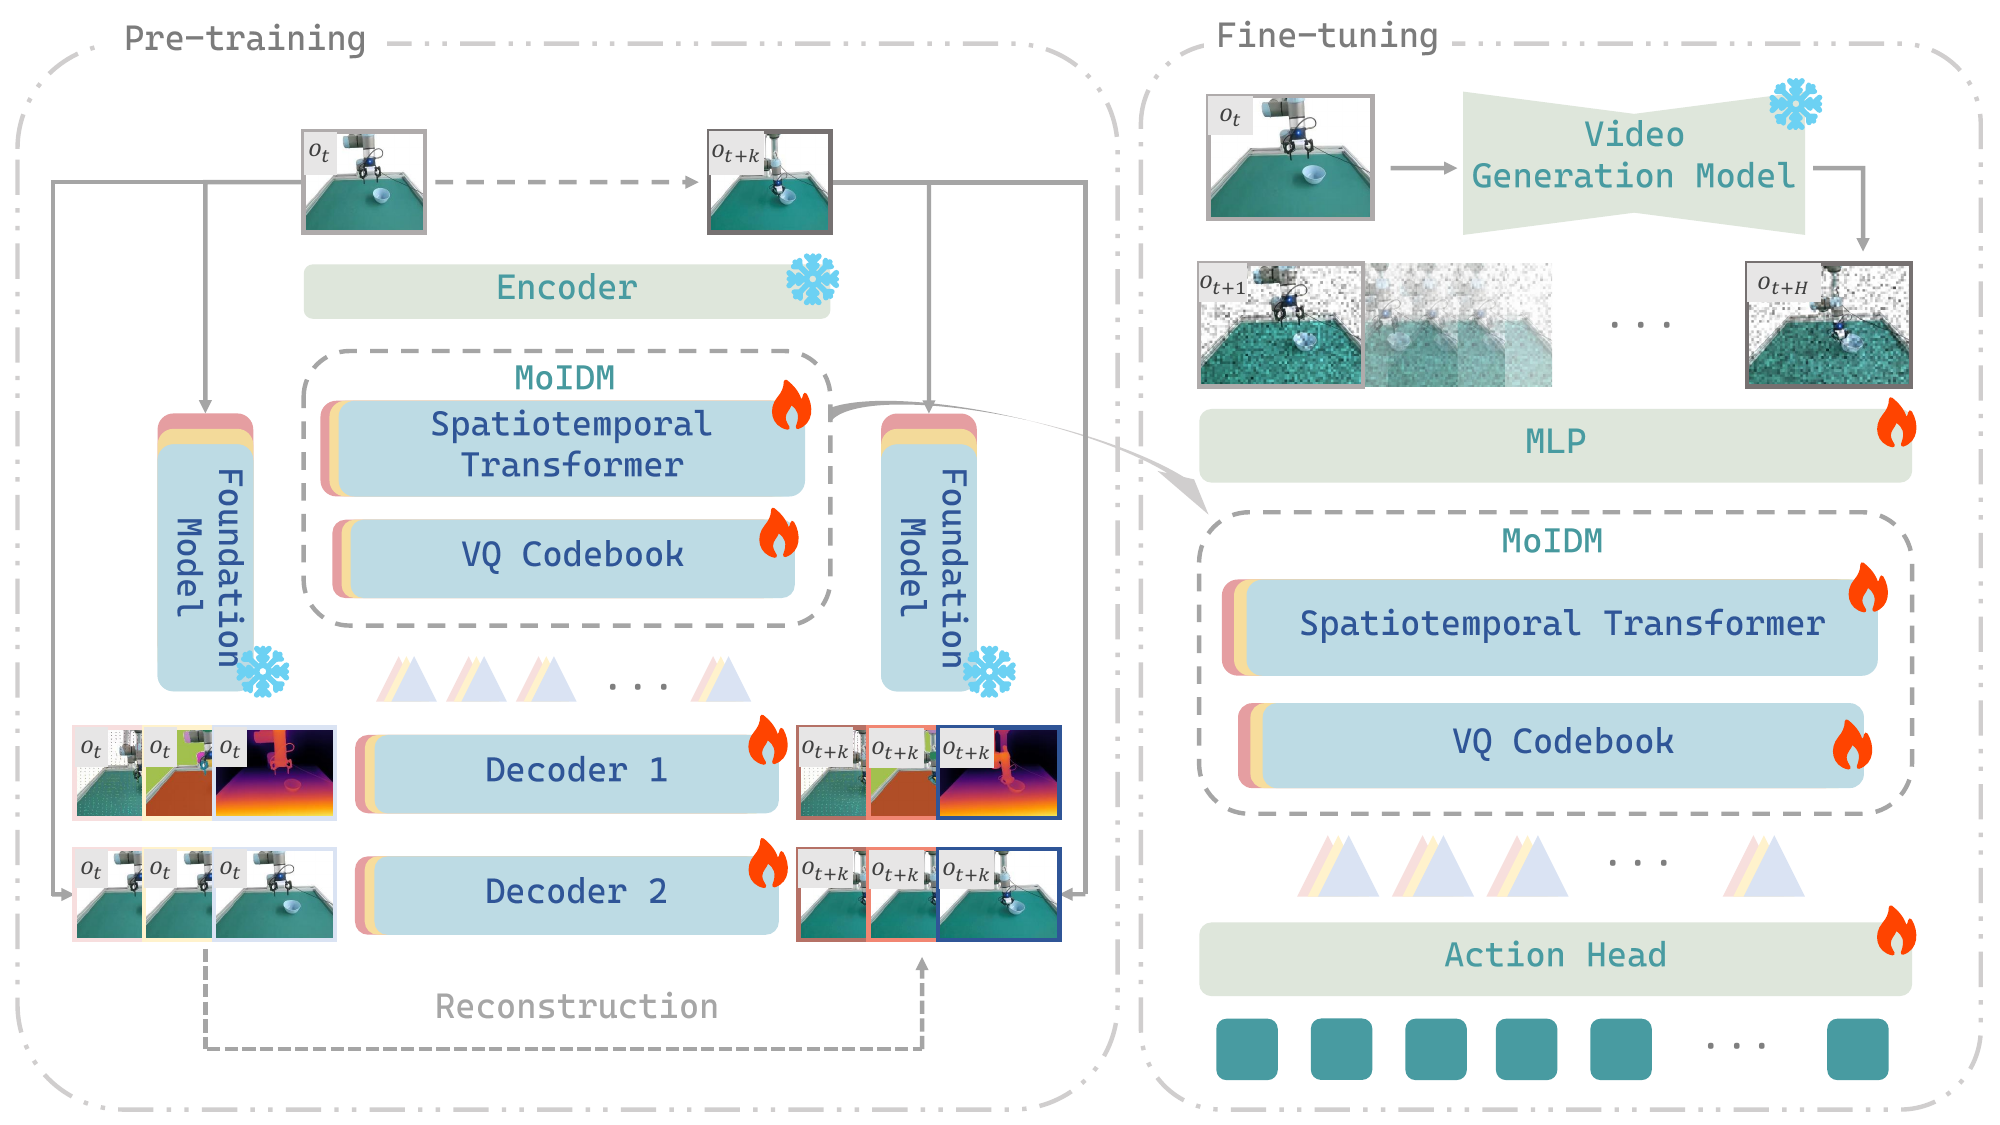
From Imagined Futures to Executable Actions: Mixture of Latent Actions for Robot Manipulation
Yajie Li*, Bozhou Zhang*, Chun Gu, Zipei Ma, Jiahui Zhang, Jiankang Deng, Xiatian Zhu, Li Zhang
- TL;DR: We introduce MoLA, which transforms imagined future videos into executable representations through a mixture of pretrained inverse dynamics models, achieving consistent gains in simulation and real-world robot manipulation.
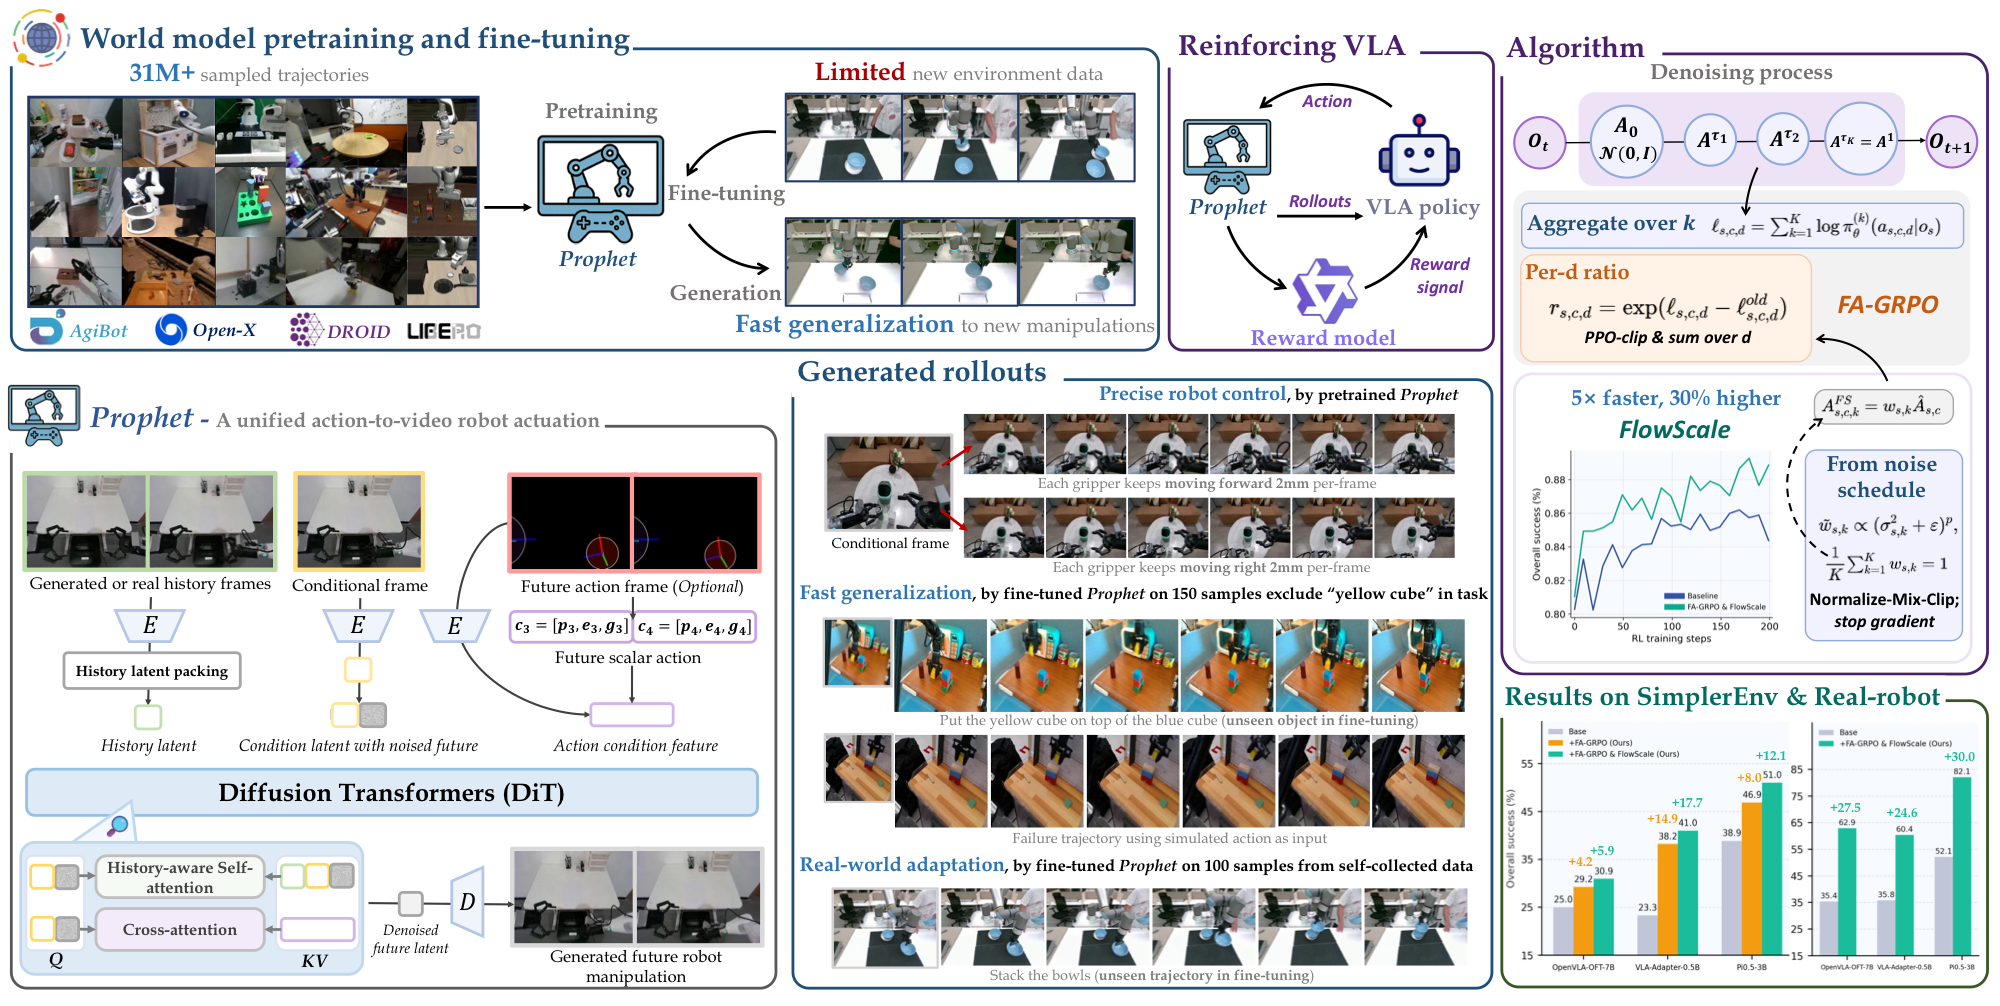
Reinforcing Action Policies by Prophesying
Jiahui Zhang*, Ze Huang*, Chun Gu, Zipei Ma, Li Zhang†
- TL;DR: We introduce ProphRL, which learns a reusable action-to-video world model and a flow-aware RL post-training strategy to improve VLA policies efficiently, delivering strong gains in both simulation and real-robot tasks.
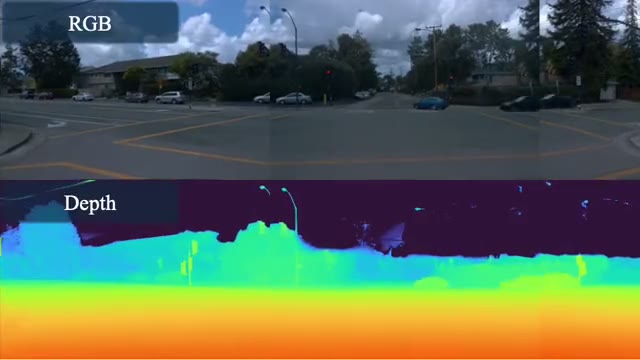

BézierGS: Dynamic Urban Scene Reconstruction with Bézier Curve Gaussian Splatting
Zipei Ma*, Junzhe Jiang*, Yurui Chen, Li Zhang†
- TL;DR: We propose a method that models object motion using Bézier curves, achieving accurate reconstruction and effective foreground-background separation.
🎓 Academic Service
- Conference Reviewer: ICML, AAAI
📖 Educations
- 2025.06 - Present, Fudan University & SII
- 2021.09 - 2025.06, Sun Yat-sen University
🤣 Hobbies
- 🏸 Badminton, ⚽️ Football(Visca el Barça! 💙❤️)
- 🎮 Games(Soulslike, Multiplayer…)
- 🎬 Movies, 🎵 Music